
-
 products/IMG_6729.jpg
-
 products/IMG_6860_d2cc39d1-f844-4431-8233-7039f20b16dc.jpg
-
 products/IMG_6721.jpg
-
 products/IMG_6722.jpg
-
 products/IMG_6725.jpg
-
 products/IMG_6727.jpg
-
 products/IMG_6730.jpg
-
 files/O1CN01h3MSHQ2DtzvpKOVLg__2215716588668_54e60f8b-a9aa-4ff1-b672-6a0327e968e1.jpg


- Regular price
- $32.00
Shipping And Service
Shipping And Service
About point
About point
(lower right corner of the store page):
★5 points for every $1 spent;
★For every 100 points redeemed, you can get a $1.00 discount on the entire order;
Applicable to orders of any amount.
How to use points:
1. Redeem in the smile panel.
2. Redeem at checkout.


Product Description
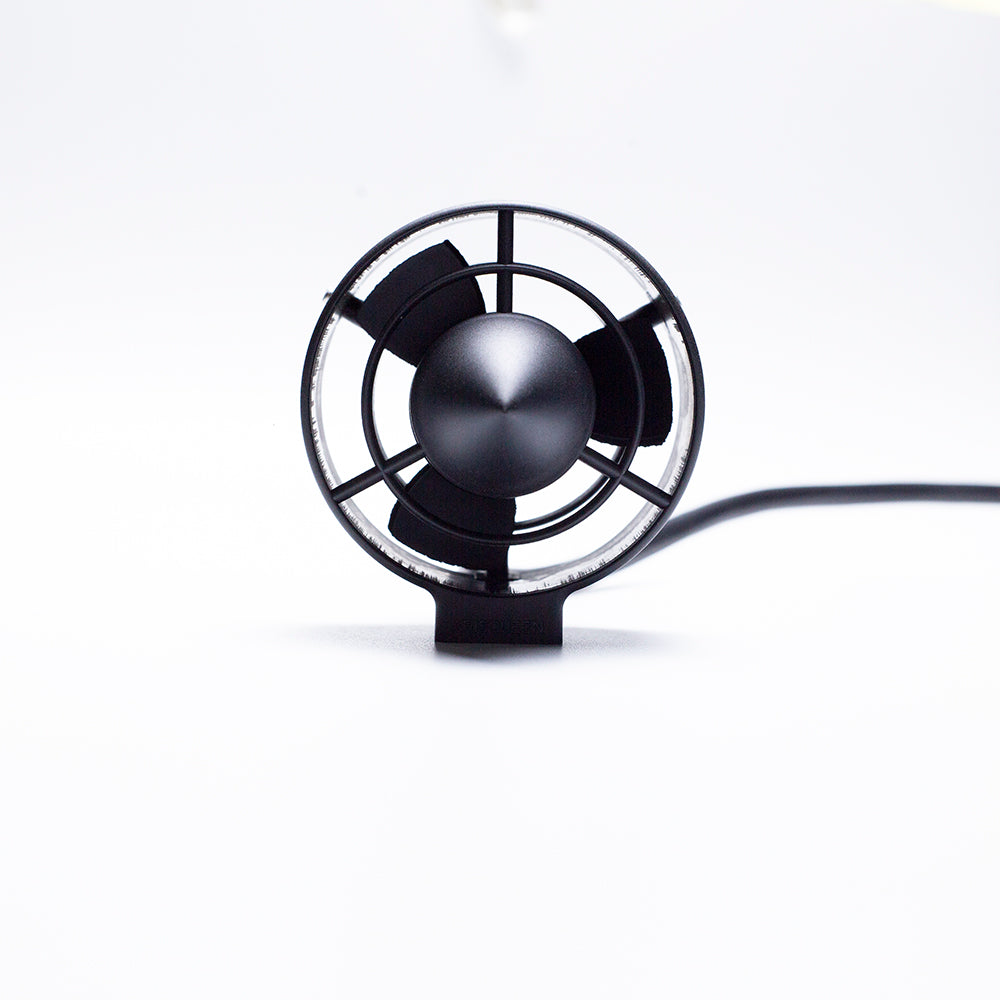
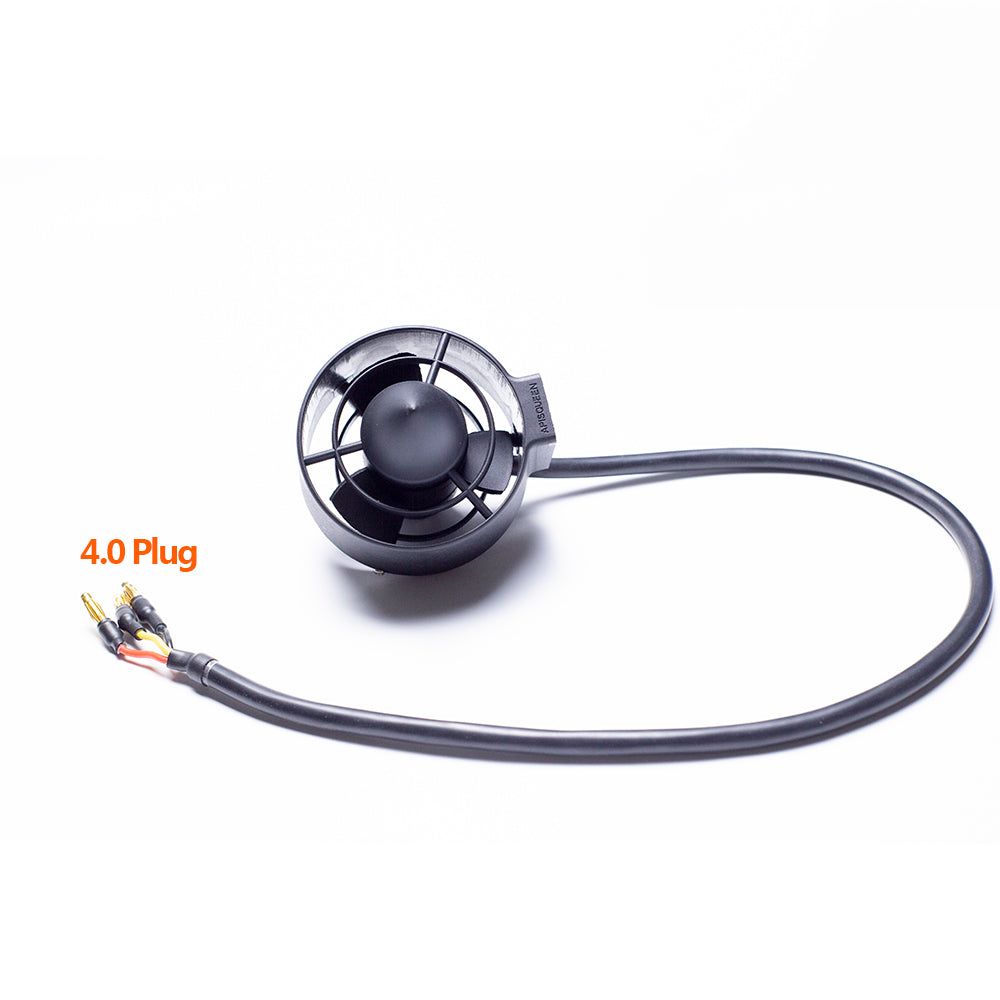
APISQUEEN U2 Mini 192W Brushless Underwater Thruster
The APISQUEEN U2 Mini is a compact brushless underwater thruster designed for small ROVs, underwater robots, and other compact aquatic propulsion systems.
Operating at 12–16V, the U2 Mini delivers up to 192W of power with a maximum current of 12A. Its compact structure, lightweight design, and protective ribs make it suitable for space-limited underwater applications.
Available in CW and CCW rotation options, the U2 Mini can be integrated into multi-thruster propulsion systems with a compatible ESC and PWM control signal.
Features
1: U2 mini brushless underwater thruster one piece open mold, using composite materials, anti-corrosion and anti-oxidation, can be used in seawater environment.
2: U2 mini low power consumption, high efficiency.
3: U2 mini front and rear protective ribs, which can effectively block the entry of foreign objects.
4: the use of motor 500KV, high speed.
5: support up to 16V (4S LiPo).
U2mini Specifications
Model:U2 Mini
Motor Type:Brushless DC
Operating Voltage:12–16V
Battery Compatibility:3–4S LiPo
Maximum Power:192W
Maximum Current:12A
Maximum Thrust:2.2 kg
Motor KV:500KV
Control Signal:PWM, 1–2ms, 50Hz
Dimensions:95.8 × 76.95mm
Weight:210g
Cable Length:150cm
Wire Diameter:7mm
Rotation:CW / CCW
Operating Environment:Freshwater / Seawater
U2 mini underwater thruster usage video tutorial (No ESC/With ESC):


Dimension Drawing

APISQUEEN U2 mini Underwater Propulsion 3 D Drawing Download
ABOUT PWM
PWM full name is (Pulse-width modulation). It is also called duty cycle signal, which indicates the proportion of the high level duration to the whole signal period. 2ms for the whole period of PWM, 1.5ms stop, 1.5-2ms forward, 1.5-1ms reverse.
From the diagram, we can clearly see that when PWM is 75% (1.5ms), the motor stops rotating, when PWM is 50% (1ms), the motor rotates in reverse, and when PWM is 100% (2ms) the motor rotates in forward.Of course ESC will not only make the motor turn forward and reverse, but can adjust the speed of motor rotation by the duty cycle size of PWM. When the PWM is gradually changed from 75% to 50%, the motor will keep reversing and accelerating from stop until the reverse rotation reaches the maximum. And when PWM is gradually changed from 75% to 100%, the motor is continuously accelerated from stop to forward until the forward rotation reaches the maximum value. That is, PWM is a signal that can be continuously varied, and the effective range is from 50% to 100%.
The frequency of PWM signal is 50hz, 100hz, 200hz or 500hz, etc. The higher the control frequency, the shorter the period, the shorter the control interval, and the faster the ESC and motor response speed The faster the ESC and motor response. Conversely, the lower the control frequency, the longer the period, the longer the control interval, and the slower the ESC and motor response.
U2 Single Thruster Test Table


FAQ
Q1: What is the difference between the CW version and the CCW version?
DESCRIPTION OF THE UNDERWATER THRUSTERS CW AND CCW
Q2:How can I use a Raspberry Pi 4B to send a PWM signal to an ESC to control an underwater thruster?
How can I use a Raspberry Pi 4B to send a PWM signal to an ESC to control an underwater thruster?
Example code:
import pigpio
import time
pi = pigpio.pi() #create pigpio object
LED_PIN = 18 # Define the GPIO port to which the LED is connected.
PWM_FREQUENCY = 50 #define the PWM frequency in Hz
PWM_range = 1000
PWM_DUTYCYCLE = 0 # Define PWM duty cycle, value range 0 (2) 55,
pi.set_mode(LED_PIN, pigpio.OUTPUT) #Set the GPIO port to output mode
pi.set_PWM_frequency(LED_PIN, PWM_FREQUENCY) #set PWM frequency
pi.set_PWM_range(LED_PIN, PWM_range) # set range 1000
pi.set_PWM_dutycycle(LED_PIN, 75) # set PWM duty cycle 75/1000=7.5 per cent
time.sleep(3) # delay 3s unlock successful
pi.set_PWM_dutycycle(LED_PIN, 100)
# Positive rotation 7.5%-10% duty cycle, the larger the duty cycle, the faster the positive rotation speed
time.sleep(15)
pi.set_PWM_dutycycle(LED_PIN, 60)
# Reverse The closer the duty cycle is to 5%, the faster the reversal speed is
time.sleep(5)
pi.set_PWM_dutycycle(LED_PIN, 75)
# Duty cycle
time.sleep(5)
Q3: How do I select compatible equipment for the U2mini?

